I. How a Vibračný miskový podávač Works with an Assembly Machine
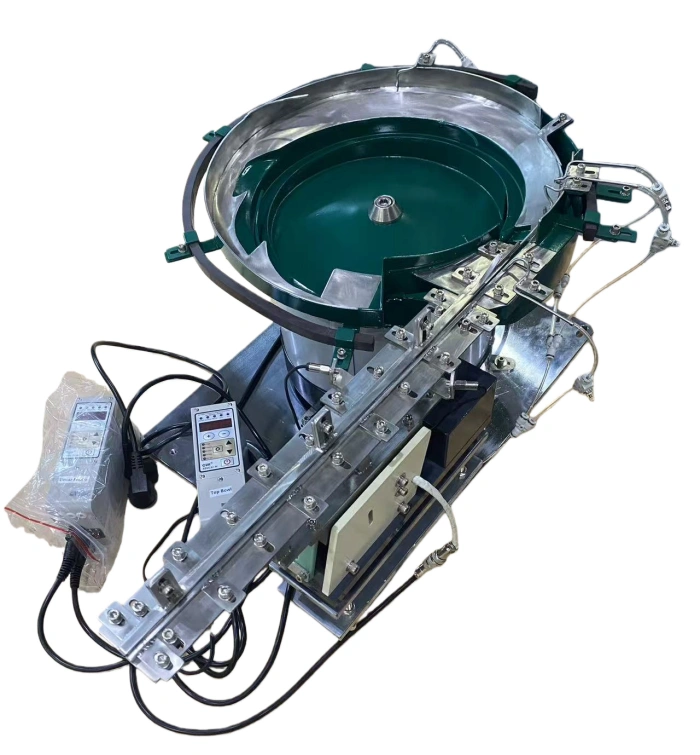
The vibratory bowl feeder acts as the parts supply source for the assembly machine. Its role is to sort, orient, and singulate parts, then deliver them one by one to the assembly machine’s pick-up point. The typical workflow is as follows:
| Step | Action |
|---|---|
| 1 | Bulk parts are loaded into the vibratory bowl feeder |
| 2 | The bowl vibrates, moving parts up a spiral track |
| 3 | Track tooling (wipers, slots, air jets) orients each part correctly |
| 4 | Parts exit the bowl and enter a linear feeder (straight track) |
| 5 | A sensor at the end of the linear feeder detects a part is ready |
| 6 | The sensor sends a signal to the assembly machine’s PLC or controller |
| 7 | The assembly machine’s pick-and-place mechanism (robot, gripper, or vacuum) picks the part |
| 8 | The assembly machine performs its operation (screwing, pressing, inserting, etc.) |
| 9 | The sensor detects the part is gone and signals the bowl to advance the next part |
| 10 | The cycle repeats |
II. Key Components for Integration
| Component | Purpose |
|---|---|
| Linear feeder (straight track) | Transfers parts from bowl exit to the pick-up position |
| Part-present sensor | Detects when a part is ready at the pick-up point |
| Pick-up nest / fixture | Holds the part in a precise, repeatable position |
| Escapement mechanism (optional) | Separates one part at a time from the single-file stream |
| PLC or relay logic | Manages the handshake between bowl feeder and assembly machine |
| Communication interface | I/O signals, Ethernet, Profinet, or Modbus for data exchange |
III. Issues That Need Attention
A. Mechanical Alignment
| Issue | Impact | Solution |
|---|---|---|
| Height mismatch | Bowl exit does not align with assembly machine pick-up point | Adjust bowl base height or use a linear feeder with adjustable angle |
| Misaligned track | Parts jam or fall off during transfer | Align linear feeder with bowl exit and pick-up nest |
| Loose mounting | Vibration causes misalignment over time | Bolt bowl and linear feeder securely to a rigid frame |
B. Timing and Synchronization
| Issue | Impact | Solution |
|---|---|---|
| Bowl feeds faster than assembly machine can pick | Parts pile up at pick-up point; jams occur | Use a sensor to stop the bowl when part is present; restart when picked |
| Assembly machine waits for parts | Low efficiency; machine idle time | Increase bowl speed or reduce assembly cycle time; add buffer track |
| Signal delay | Assembly machine picks before part is fully seated | Adjust sensor position or add a short delay in PLC program |
C. Part Orientation and Quality
| Issue | Impact | Solution |
|---|---|---|
| Wrong orientation | Assembly machine picks part incorrectly; defective assembly | Improve track tooling; add vision system for verification |
| Deformed or defective parts | Assembly fails; machine jams | Add inspection station (vision, laser, or mechanical gauge) before pick-up |
| Part variation (size, weight) | Inconsistent feeding; jams | Verify part quality; adjust track gap; use flexible feeder if needed |
D. Sensor and Control Integration
| Issue | Impact | Solution |
|---|---|---|
| Sensor false trigger | Bowl stops or starts incorrectly | Use appropriate sensor type (photoelectric, fiber optic); shield from dust and vibration |
| Communication error | Assembly machine and bowl feeder out of sync | Use standard protocols (EtherNet/IP, Profinet); check cable connections |
| No part-present signal | Assembly machine waits indefinitely | Test sensor; verify PLC program logic; check wiring |
E. Maintenance and Environment
| Issue | Impact | Solution |
|---|---|---|
| Dust or oil accumulation | Sensor failure; track clogging | Clean regularly; use air purge on sensors |
| Vibration transfer | Affects assembly machine accuracy | Isolate bowl feeder with rubber mounts; use separate frames |
| Noise | Operator discomfort | Add soundproof enclosure if noise exceeds 80 dBA |
| Static charge | Parts stick to track; sensors misread | Install ionizing blower near pick-up point |
IV. Best Practices for Integration
| Practice | Reason |
|---|---|
| Use a linear feeder between bowl and assembly machine | Provides a buffer and ensures consistent part presentation |
| Install a part-present sensor at the pick-up point | Prevents overfeeding and ensures the assembly machine picks only when a part is ready |
| Mount bowl feeder and assembly machine on separate frames | Isolates vibration; prevents accuracy loss |
| Provide a reject chute for defective parts | Removes bad parts before they reach the assembly machine |
| Use quick-change tooling in the bowl | Reduces changeover time when switching products |
| Keep spare springs, sensors, and belts in stock | Minimizes downtime |
| Train operators on basic troubleshooting | Enables fast response to jams or sensor issues |
V. Summary Table
| Aspect | Key Points |
|---|---|
| How they work together | Bowl sorts/orients → linear feeder transfers → sensor detects → assembly machine picks |
| Mechanical alignment | Height, track alignment, rigid mounting |
| Timing | Sensor-controlled start/stop; PLC synchronization |
| Orientation | Track tooling; optional vision verification |
| Sensor integration | Part-present detection; communication with PLC |
| Maintenance | Clean sensors; check springs; isolate vibration |
| Best practices | Linear feeder, part-present sensor, separate frames, reject chute |

 Slovak
 English
 Spanish (Mexico)
 Czech
 Arabic
 Russian
 German
 French
 Turkish
 Italian
 Ukrainian
 Polish
 Romanian
 Bengali
 Portuguese (Portugal)
 Thai
 Japanese
 Korean
 Hebrew
 Uzbek
 Hindi
 Vietnamese
 Portuguese (Brazil)
 Spanish (Peru)
 Spanish (Spain)
 Spanish (Venezuela)